
Autoresearch, and the first map
Napkin math argument that our current understanding of the universe is closer to the earliest surviving map than the next few decades.
2026.09.22 3 min autoresearch · digital twin · eacc · simulation

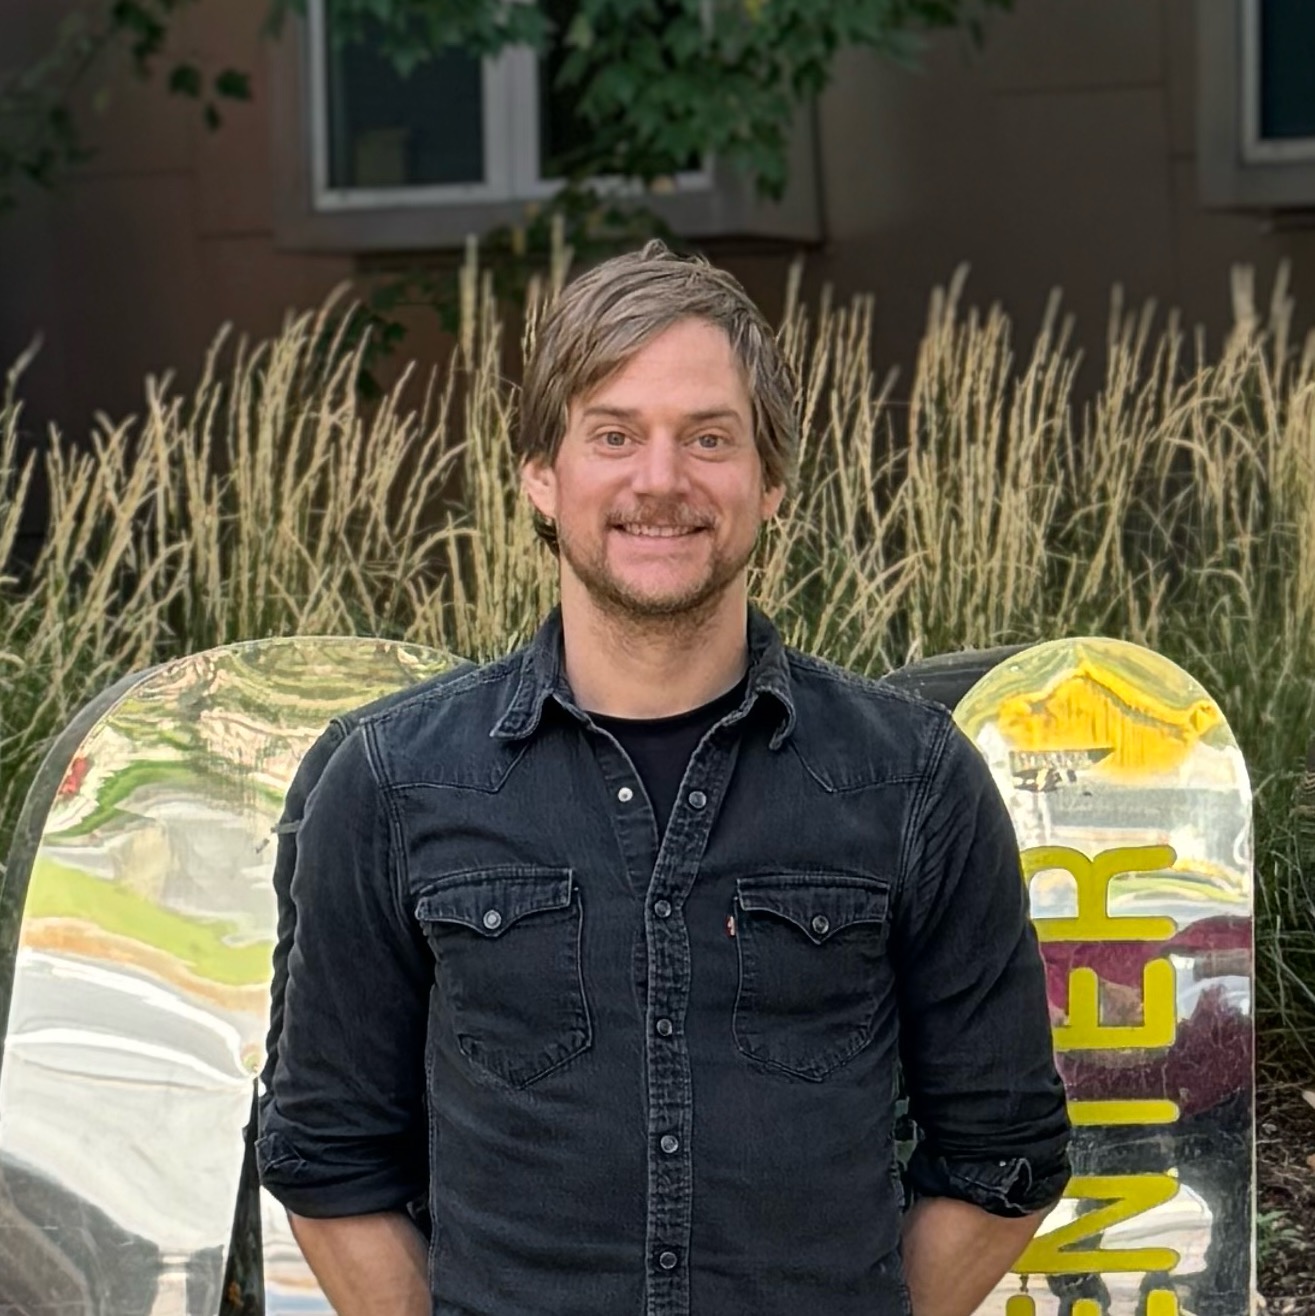
I'm a research engineer in autoresearch and simulation. I'm interested in world models and their potential for automating robotic policy training and evaluation. I'm a researcher with the Harvard Computational Robotics Group.
I previously was senior AI/ML at Anduril and founded a spatial computing startup that was used thousands of research institutions and every top 100 university in the world. I also led an influential project that applied strategies from city simulations to improve control policies for large heterogeneous Multi-Robot Systems.
Outside of my research, I co-founded an NGO for furthering education about 3d graphics and practice western-style boxing.
Control groups of robotics and other agents from multiple vendors to collaborate in problem solving with an LLM, world model, and VLA. Evaluated on GDM Melting Pot, SC2, CtF, and similar problems.
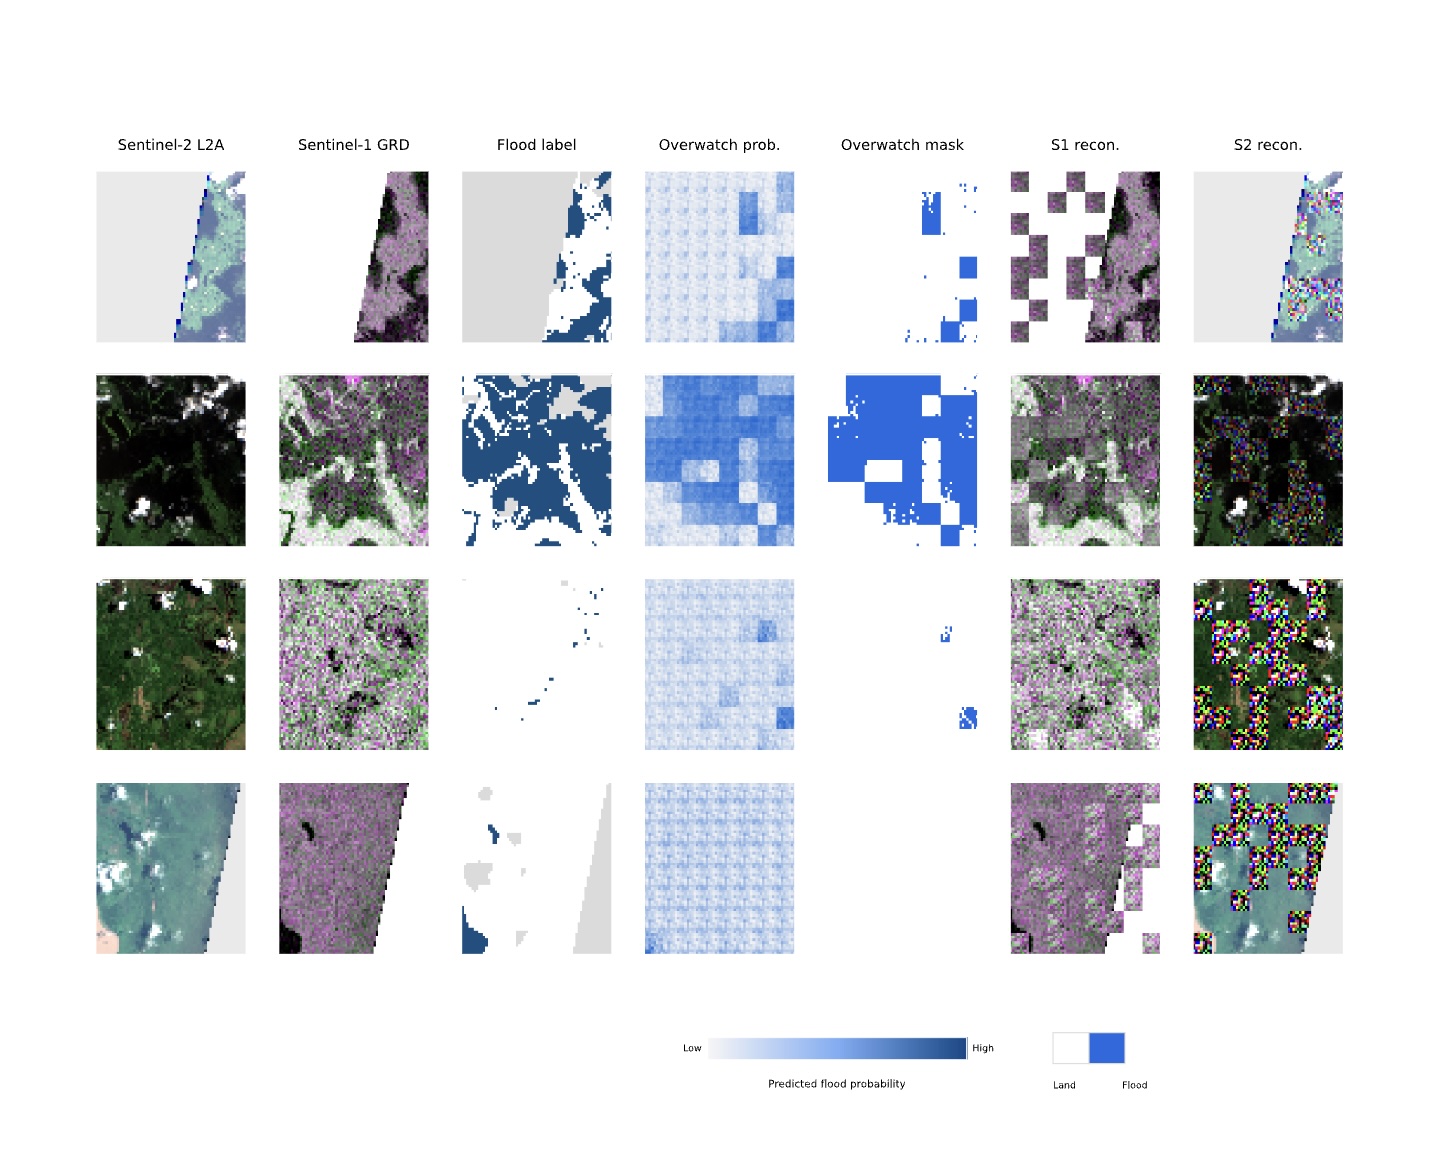
Foundation geospatial model trained on multispectral remote sensing data to rapid evaluate change, land usage, flood tracks, and data imputation against noise.
Agent skills that complete experiment design, data source selection and preprocessing, running regressions and other analysis, and interpreting results across a wide range of fields.
Create a 3D world simulation with live geospatial data. Used for counterfactual analysis, training, and risk assessment.
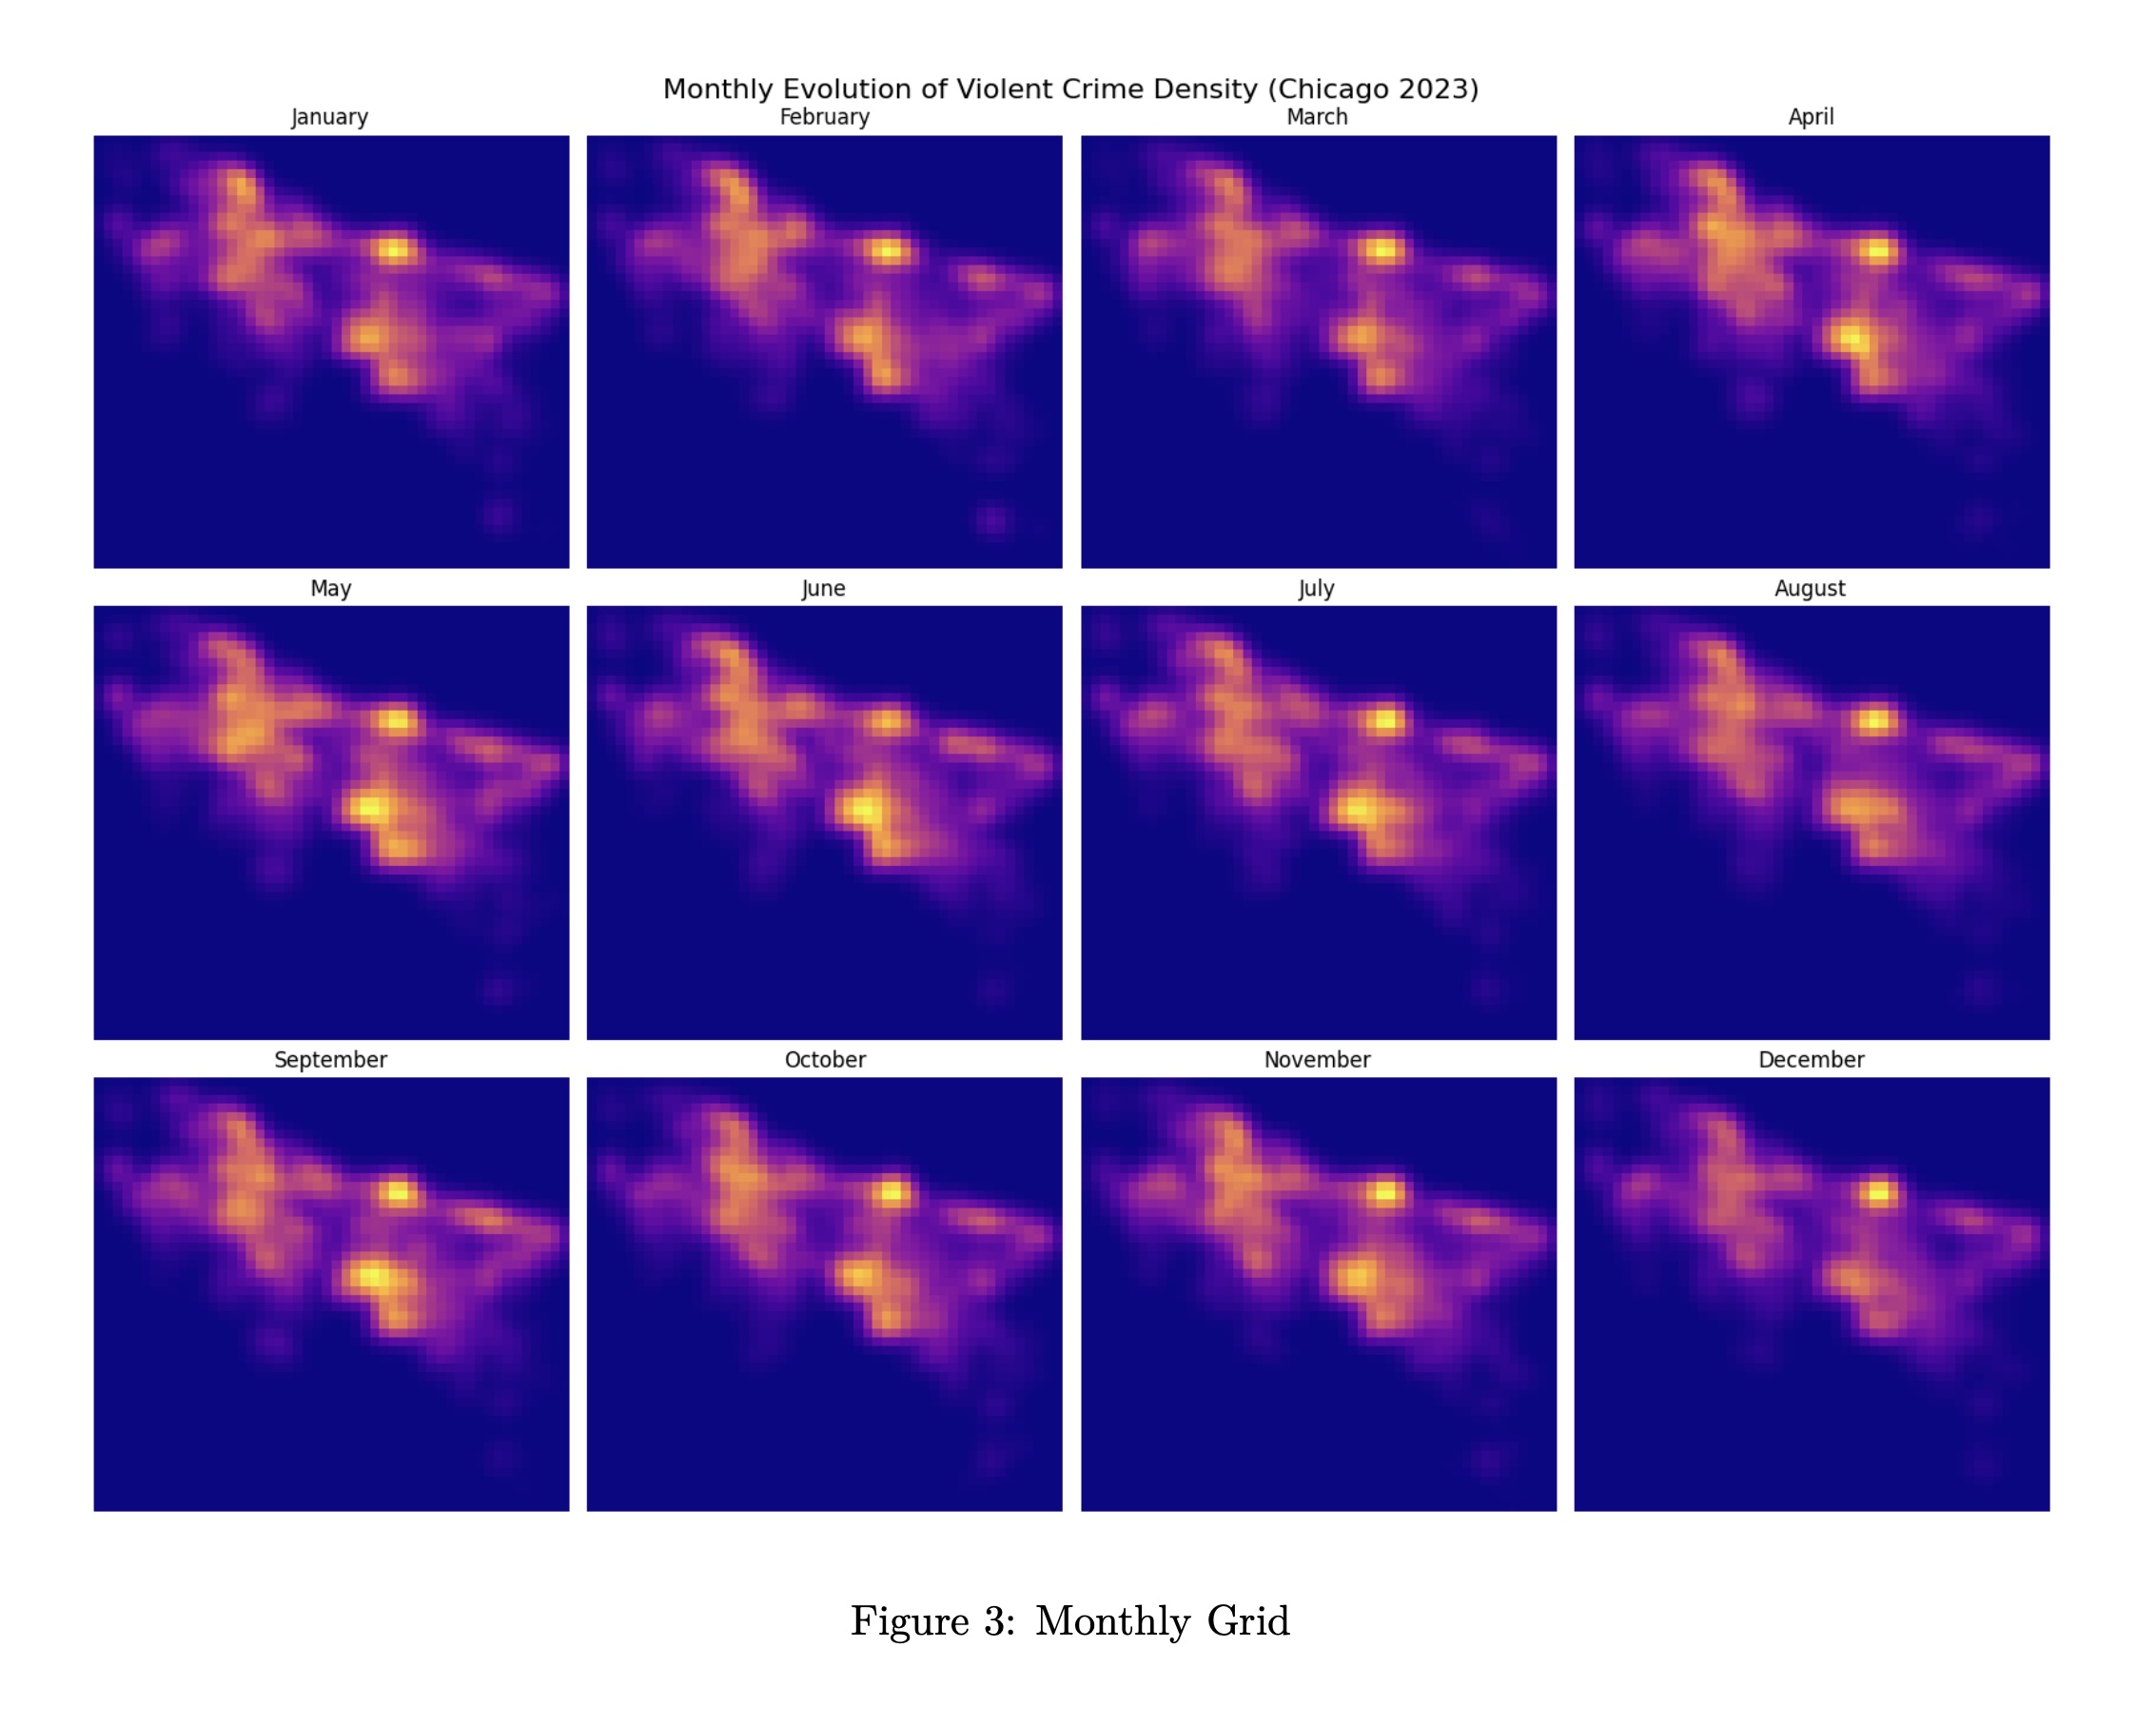
Estimate causal effects from diverse multimodal spatiotemporal data streams
 Reuters
 Wired
 Reddit
 Hacker News
 BBC
 CNN
 National Geographic
 The Guardian
 Smithsonian
 PBS
 Google
 OpenAI
 Harvard Gazette
 The Harvard Crimson
 University of Chicago
 Lonely Planet
 Matterport
 Polycam
 Replicate
 LiveScience
 Sharp
 Nerdist
 Washington Post
 Boston Globe
 My Modern Met
Patent-pending systems and methods for probabilistic world-state estimation and forecasting from heterogeneous real-world observations.